2014-01-23

68008 SRAM Microcomputer – Free Run

Hello,

yesterday i searched for some of the parts and put the 68008 on the bread board. According to other projects it is possible to do a "free run" by pulling all data lines to low. Though some people say it's the opcode of NOP it actually is some kind of ORI.

I wanted to check some prerequisites of the project:
  1. Does the CPU work?
  2. Can !DTACK (data acknowledge) be held permanently low?
  3. Can !VPA (valid peripheral address) be used for instruction fetch cycle? 
ad 1: Yes the CPU works. It cycles through it's address space and toggles A19 with 2 Hz.
ad 2: Yes, as i could tell the CPU works. :-)
ad 3: For curiosity: Yes. I believe that bus cycles and internal logic are completely separated and !VPA can be used for any bus cycle.

Next interesting question: Can i put videos in my blog? It seems i can, but for a final verification i probably have to publish this page.

Update: They are just converted into poor animated GIFs. I'll have to find something better... ok, uploaded them to youtube and embedded. back to the roots...


Free Run using !DTACK-terminated bus cycles
To the left is the 68008 on my bread board and wired up to us !DTACK to terminate bus cycles. !DTACK is permanently low (active) and the CPU runs as fast as it can: At 8 MHz it does 2 opcode fetches per µsec or 2,000,000 opcode fetches per second. As the whole address space of the 68008 is 1 MB only, it cycles through it's address space 2 times a second. The most significant address bit A19 should blink with 2 Hz. A19 is the leftmost LED in the video and i hope you can verify that it blinks with 2 Hz. Thanks.

An important result is that the 68008 actually works without deactivating !DTACK after each bus cycle. Though in all timing diagrams bus cycles start with !DTACK high it is actually possible to keep it low the whole time.


Free Run using !VPA-terminated bus cycles
In the second video i used !VPA to terminate the bus cycles instead. This mode is intended to access old (really old!) 6800 peripherals but it seems true that you can terminate any bus cycle with !VPA, even an opcode fetch cycle. It's just slower. I was curious how slow actually, if every bus cycle uses !VPA, because the 68008 data sheet say it can be from 11 to 18 clock cycles long.

Actually the M68000 8-/16-/32-Bit Microprocessors User’s Manual Ninth Edition says 10 to 19 cycles, while the M68000 Family Reference Manual – MC68008 Technical Summary says 11 to 18 cycles.


Buggy timing diagram for the 'best case' !VPA-terminated bus cycle
The latter puzzled me, because of course i started with the 68008 documentation, because that's the CPU i'm using, and i was wondering how fast the 68008 could uninterruptedly access the bus using the !VPA mode as 11 cycles is slower than the period of the free running E signal to which !VPA bus cycles are synchronized. But 10 to 19 makes sense (while 11 to 18 makes not) and i found an unnamed cycle in the 68008 manual's 'best case' chart (between the last 'w' cycle and 'S5') and i believe that someone reviewed the charts, found that the 'worst case' chart was only 18 cycles instead of 19 cycles long, demanded a correction and the missing cycle was added ... to the wrong chart. That's how real world works.

In the second video one bus cycle takes 10 clock cycles instead of 4 and therefore A19 should blink with 2 Hz *4 / 10 = 0.8 Hz instead. I think this approximately true.

In my project the !VPA bus cycle is used to access slow peripherals on the K1 bus. But it is also used during interrupt acknowledge, in order to use an auto vectored interrupt. Now the interesting question is: Does the CPU actually perform a !VPA controlled bus cycle here or a dummy cycle, as it ignores the byte read?


!VPA used in interrupt vector read cycle
My guess was, that it actually does a !VPA controlled slow bus cycle if you activate !VPA, making interrupts approximately 10 clock cycles slower. And finally i found this chart on the last (!) page of the M68000 8-/16-/32-Bit Microprocessors User’s Manual Ninth Edition. The last pages are appendix B which is about interfacing 6800 devices and which are pasted into the document as bitmaps only. :-)

The bus interface performs a slow memory cycle in the (dummy) interrupt vector read cycle if !VPA is activated to request an auto vector interrupt.


2014-01-19

68008 SRAM Microcomputer – Unused 2-to-4 Line Decoder Got a Job!

browsing through some other 68008 projects in the web
i was reminded to the fact, that the 68000 has something called short addressing: Instead of supplying a 4-byte long address you only supply a 2-byte short address which is sign-extended to 4 bytes. This saves space in program code and – more important – up to 8 CPU clock cycles. So i took a look at my current address layout:

v0.2 address decoder

This allows the first 32k of RAM to be accessed with short addressing as well as the slow I/O address range, but not the fast I/O range:
  • %xxxxxxxx,xxxx00xx,xxxxxxxx,xxxxxxxx selects RAM and
    %00000000,00000000,0xxxxxxx,xxxxxxxx is a possible subset of this which fit's in a signed word.
  • %xxxxxxxx,xxxx01xx,xxxxxxxx,xxxxxxxx selects ROM and can never be accessed with short addressing.
  • %xxxxxxxx,xxxx11xx,xxxxxxxx,xxxxxxxx selects slow I/O and
    %11111111,11111111,1xxxxxxx,xxxxxxxx is a possible subset of this which fit's in a signed word as a negative value.
  • %xxxxxxxx,xxxx10xx,xxxxxxxx,xxxxxxxx selects fast I/O and can never be accessed with short addressing.
In order to make all I/O short addressable, all I/O must have A31 .. A15 high. A18 cannot be used to select between slow and fast I/O. The first Address line which can be used for that is A14:

v0.3 address decoder

Now the memory map is as follows:
  • %xxxxxxxx,xxxx00xx,xxxxxxxx,xxxxxxxx selects RAM and
    %00000000,00000000,0xxxxxxx,xxxxxxxx is a short addressable subset.
  • %xxxxxxxx,xxxx01xx,xxxxxxxx,xxxxxxxx selects ROM (no short addressable subset).
  • %xxxxxxxx,xxxx1xxx,x1xxxxxx,xxxxxxxx selects slow I/O and
    %11111111,11111111,11xxxxxx,xxxxxxxx is a short addressable subset.
  • %xxxxxxxx,xxxx1xxx,x0xxxxxx,xxxxxxxx selects fast I/O and
    %11111111,11111111,10xxxxxx,xxxxxxxx is a short addressable subset.
There is no need to apply the post-reset INIT line pull-up to A14 for the I/O address decoder and there is no need to strobe the outputs with !AS because the I/O control lines are strobed by !AS directly at the 74HC138 which generates them (see other sheet – next to come :-)). It's even better this way because now !SLOW_IO which is directly connected to the CPU's !VPA input to request slow I/O or an auto vector toggles before !AS is valid and not shortly thereafter.

Funny Note

Actually this second 2-to-4 line decoder could be replaced entirely by one NAND gate: !FAST_IO is not used anywhere (actually it is currently used to reset the INIT line, but this could have been !SLOW_IO as well) and !SLOW_IO becomes low when A14 and A19 are both high, so, yes, that's a NAND function. The NAND gate would even be faster (the 74HCT139 is pretty slow) but – i don't have a spare NAND gate, but i had a spare 2-to-4 line decoder. :-)


2014-01-18

68008 SRAM Microcomputer – Reset circuit (Updated)

Now to something very simple which i always have problems with: The reset circuit. It's only made from few parts but it's ANALOGOUS. (shiver!)

Let's start with the requirements: 

For unknown reasons the 68008 CPU needs an excessively long reset pulse after power-up: 0.1 seconds! Because there are other circuits which may pull !RESET low, most namely the CPU itself, !RESET must be driven with an open collector or open drain output.

To the right is an image of the current circuit:

Let's discuss it. 
This is very important because it's analogous and most times my analogous stuff doesn't work. :-/

Start with R9 + R4 and ignore the rest: These two resistors form a voltage divider for Vcc and the voltage in the middle is 2.5V. (5V/2)

Now add the capacitor: Initially it is discharged and behaves like a piece of wire. But as time goes by and current flows through it (and through the voltage divider) it charges and voltage across it increases which subtracts from the voltage present at the voltage divider. So the middle voltage of the voltage divider starts at 2.5V and drops over time to zero.

Next add transistor T1: The first effect is that the middle voltage is shorted by the base-emitter diode of T1 to ground, so the middle voltage is initially 0.7V, which is the break-through voltage of the diode, stays at that voltage for a while until it drops below 0.7V and resumes dropping as with no transistor present.

While there is current sinked through the base-emitter diode, the transistor switches on, sinking the !RESET line to ground. As soon as the base-emitter voltage drops below 0.7V the transistor will switch off and !RESET rises to Vcc. We only have to choose the capacitance and the resistors appropriately, so that this will happen after approximately 0.1 second.

But that's only half of the story: The transistor is not switched on or off depending on the voltage at it's base pin, instead the amount of current it can sink is a function of the current through the base-emitter diode. While this diode keeps the voltage at the base pin at 0.7V, the current through the diode needed to do this decreases as the voltage at the voltage divider decreases. So at some point in time the transistor is no longer fully able to sink all current from the !RESET line but only a part of it and the voltage on the !RESET line will not switch instantaneous to Vcc but will rise slowly.

This is totally unreliable. !RESET must go away very fast, ideally within one CPU clock cycle. This is where T2 and it's two associated resistors enter the game: While !RESET is low T2 is switched off and the circuit behaves as if T2 wasn't there. But when !RESET slowly rises above 0.7V T2 will start to sink current. This will subtract from the base current of T1 which will in return sink less current from the !RESET line and the voltage on the !RESET line rises even more which will open T2 more which will ... Yes, a positive feedback and !RESET will rise very fast once it has reached 0.7V.

Now let's examine power-up and power-down behavior.

At power-up C1 is empty. But the state of the !RESET line is unknown. If it rises with Vcc then T2 will be open right from the start and may finish the reset pulse before it has been activated at all. It's very likely that it will do this because of the pull-up resistor on the !RESET line. To prevent this the voltage at the base of T1 must be asserted to be clearly above 0.7V when C1 is empty: This is true with the given values for R4, R9 and R12 (all 50kΩ) because when C1 is empty the voltage at the voltage divider will be 1/3 Vcc which is approximately 1.65V and which will be sinked through the base-emitter diode of T1, opening T1 which will pull !RESET low. Check.✓

After a while capacitor C1 is loaded (nearly) to Vcc and the input of the voltage divider is Vcc minus Vcap which is (nearly) 0V. When power is switched off, Vcc drops to 0V but the capacitor is still loaded, so the voltage at the voltage divider drops to -Vcc. We'll have to check the circuit that this does no harm. Check.✓

Now the capacitor must be discharged, so that it is discharged when power is switched on again. This happens through the voltage divider R4+R9 in approximately the same time as was required to load the capacitor after power-on. Check.✓

Last step: calculate the values.

!RESET is pulled up by a 5kΩ resistor which sources 1mA at Vcc=5V and there is some more circuitry attached, so let's say T1 must sink 5mA.

T1 may have a current amplification of 100 (this is a value which widely varies even for transistors of the same type) so the base-emitter current of T1 must be ~ 0.05mA.

This current must be sinked through the base-emitter diode of T1 even after C1 has charged to – let's say – 1/2 and the remaining voltage at the voltage divider is 2.5V. This leaves a voltage drop of ~2V across R9. Using the formula U=R*I <=> U/I=R we calculate the value for R9 = 2/0.05e-3 = 40kΩ.

Next the capacitor voltage must rise 2.5V (see above) during 0.1s while being loaded with 0.05mA. The formula for the capacitance is: C = I*t/U. So C1 = 0.05e-3*0.1/2.5 = 2µF. Because the calculation is very rough (actually we ignore R4 which sinks some current as well and we should integrate the current over time because it's not const) so we double the capacitance. Fine adjustments will be made when it is built on the bread board. :-)

Note: You didn't remember the formula for the capacitance? Using ISO units (not inch, miles and gallons) you don't need to look up the formula, you can construct it by pure logics:

The capacitance depends on

  • Charging current: higher current => higher capacitance => C ~ I
  • Charging time: Current supplied for longer time => higher capacitance => C ~ t
  • Voltage increase during charging time: Higher voltage increase allowed => less capacitance required => C ~ 1/U
  • Using ISO units there will be no constant factor in the formula. Yeah!
  • therefore: C = I * t / U.
Alternatives

We could use a timer IC for the reset circuit, most likely a 555. But this would have a larger footprint than the discrete solution. Else we could use a mono-flop from the 74 series. But basically this increases the footprint even more (14 pin DIP instead of 8 pin DIP).

Or use a counter. But even if fed from the E output of the CPU (which is CLK/10) we'd need to count up to 100,000 for 0.1 seconds which is impractical.

I have also seen using a PIC for reset (basically because the project used a PIC for various control purposes) but using a CPU to generate the reset pulse for a CPU is a little bit ... over designed.


Update: Reset Circuit Test on the Bread Board

Today i tested the circuit and as expected it did not work as expected. Let's see why. For your convenience to the right is another image of the circuit.

As discussed above resistor R12 must be high enough so that T1 actually switches on at power-up.

Full flip requirement:

But there's another requirement for R12: It must be able to sink the whole current which flew through the base-emitter diode of T1 when T2 switches on. Else there will be some base current left at T1 and it will not fully close and therefore the voltage at the reset line will not fully rise to +5V.

To estimate this current is a little bit tricky: It depends on the pull-up current on the reset line and the transistor's current amplification. Worst case is high pull-up current and low current amplification:

• ICE = 5 mA
• hFE = 100

=> IBE ≥ 5mA/100 = 50µA

R12 ≤ UR12 / IR12 = (0.65V-0.2V) / 50µA = 9kΩ

where 0.65V = break-through voltage UBE of the transistor's base-emitter diode
and 0.2V = saturation voltage UCE between collector and emitter.

So R12 must be at most 9kΩ to ensure a full flip when T2 opens.

Power-up requirement:

Immediately after power-on we require that T1 opens, even if T2 is also open due to the pull-up resistor on the reset line. For practical reason we assume C1 not completely empty but discharged to 1V, which leaves 4V at R9. So the current across R9 is:

IR9 = (4V-0.65V) / 50kΩ = 67µA

where 0.65V = break-through voltage UBE of the transistor's base-emitter diode

This current now flows through R4, R12 and T1:

IR4 = 0.65V / 50kΩ = 13µA
IBE ≥ 50µA
IR12 ≤ (67µA-13µA-50µA) = 4µA
R12 ≥ (0.65V-0.2V) / 4µA = 112.5kΩ

where 0.65V = break-through voltage UBE of the transistor's base-emitter diode
and 0.2V = saturation voltage UCE between collector and emitter.

So R12 must be at least 112.5kΩ to ensure that T1 is initially open at power-up even if T2 is open.

Gotcha! We're trapped!

Can we solve this?

First, we were calculating with worst-case values. We could require better worst cases. Second, we can adjust R4.

Power-up requirement with new R4 value:

R4 is used to make the circuit a bit independent of the current amplification of T1 and of the pull-up current on the reset line and it is needed to discharge C1 when power is off. We can't remove it entirely but we could double it's value which will half the current through it and redo the above calculations:

IR4 = 0.65 / 100kΩ = 6.5µA
IBE ≥ 50µA
IR12 ≤ (67µA-6.5µA-50µA) = 10.5µA
R12 ≥ (0.65V-0.2V) / 10.5µA = 43kΩ

Now R12 must be at least 43kΩ to ensure that T1 is initially open at power-up even if T2 is open. Much better. :-)

Full flip requirement with reduced maximum pull-up current on the reset line:

The other two screws are the current amplification of T1 and the pull-up current on the reset line.

The allowed pull-up current was defined as 5mA which means a pull-up resistor as low as 1kΩ. Let's reduce this to 2.5mA which is still much more than we expect, because the actually used value is 5kΩ, but there may be some current added from the attached devices, though this should be negligible. Let's redo the calculations:

IBE ≥ 2.5mA/100 = 25µA

R12 ≤ UR12 / IR12 = (0.65V-0.2V) / 25µA = 18kΩ

So R12 must be at most 18kΩ to ensure a full flip when T2 opens.

Power-up requirement with reduced maximum pull-up current on the reset line:

IR4 = 0.65 / 100kΩ = 6.5µA
IR12 ≤ (67µA-6.5µA-25µA) = 35.5µA
R12 ≥ (0.65V-0.2V) / 35.5µA = 12.75kΩ

So R12 must be at least 12.75kΩ to ensure that T1 is initially open at power-up even if T2 is open.

Both requirements are met if we use 15kΩ for R12. Fine. :-)

Reset circuit with validated resistor values
To the left is the updated reset circuit as tested on the bread board. Actually i had still problems with the power-up reset if C1 was not completely empty, but that was due to a LED which i connected to the reset line to show it's state. It had clearly more than 5mA. :-)


2014-01-17

68008 SRAM Microcomputer – Main Circuit v0.2

Wow, version 0.2 of the circuit released!

i worked on the main circuit and removed 2 (two!) of the four glue logic ICs. Wow! This is near-Sinclair. I could remove one more IC and become equal-Sinclair. Or remove both remaining glue ICs and become super-Sinclair.

What does this nonsense mean?

You know i come from the Sinclair ZX Spectrum side of the universe (as opposed to the C64) and i have certain ideas about how Sir Sinclair worked. What he did was like this:

  • Use the cheapest components,
  • reduce the design to the absolute minimum
  • and then take away one more part.

That is equal-Sinclair. It seems that Sinclair is a measure for uselessness. Currently my design is only near-Sinclair, because i still could take away some parts. Let's take a look at the current circuit (version 0.2) and discuss it:

Hint: right-click on the image and open it in another window if you want to keep it visible while you read on!

Main circuit diagram with everything except the K1 bus and non-functional parts, e.g. capacitors.

As you can see there are only two glue ICs: one Quad NAND 74HCT00 and a Dual 2-to-4 line decoder 74HCT139 with only one decoder actually used.

The 2nd NAND IC7C is used as an inverter and constructs a !RD signal from the CPU's !WR signal, required by the RAM and the ROM.

The next two NANDs construct a flip flop, which is set by !RESET to indicate the initialization phase after system reset. The INIT signal from this flip flop is used to pull A18 high at the input of the 2-to-4 decoder IC2A. (The resistor R5 and the diode D2 actually construct an OR gate without wasting 3 unused gates in a 74HCT32.)

This is used to circumvent a design flaw in the 68000 microprocessor series: After reset the supervisor stack pointer and the program counter are read from addresses 0x00000.l and 0x00004.l respectively so there must be ROM mapped in. But then the whole vector table of the cpu is located here; actually roughly the first 1 kByte of memory is used for vectors. It is very desirable to have these in RAM because otherwise you cannot change them without a secondary vector table in RAM which is jumped to by the vectors in ROM. So you need ROM after reset but you prefer RAM here at any other time. The normal memory layout is RAM at address 0x00000 as you can see from the 2-to-4 decoder outputs, but during initialization A18 is pulled high so that the processor, when trying to read from address 0x00000 and 0x00004 reads from the ROM instead. After that the first memory access to the slow I/O address range will also reset the NAND flip flop and A18 is no longer forced high and the RAM can be accessed.

After we know where the !SLOW_IO signal comes from we can understand what the first NAND gate  IC7D does: If !WAIT is high and !SLOW_IO is high then the !DTACK signal to the CPU is low (asserted). The !DTACK signal is used to terminate a normal bus cycle of the CPU, either memory or other bus access. !DTACK will not be asserted when !WAIT from the K1 bus is active, thus implementing the wait processing for the K1 bus, or when !SLOW_IO is low which means a memory access to an address with A18=1 and A19=1. This memory range is used for slow I/O (sic!) and shall use the 6800 peripherals slow addressing mode, which is signaled to the CPU by pulling it's !VPA entry low instead of activating !DTACK. You can see that !SLOW_IO is directly connected to !VPA of the CPU. So either !DTACK is asserted (for the first 3 memory ranges, eventually suppressed by !WAIT) or !VPA.

Trick: Connecting !SLOW_IO to !VPA has a second effect: This also requests the CPU to use an auto-vector from it's vector table for interrupts. When an interrupt is acknowledged and the CPU reads the vector number for this interrupt, most address lines are pulled high, most notably A18 and A19, which will activate !SLOW_IO which activates !VPA which requests an auto-vector if it is pulled low during an interrupt acknowledge cycle. We only have to take precautions that this not also performs spurious I/O on the K1 bus; but that's on the other sheet. :-)

That's all about the glue logics. Not supported are:

  • Bus arbitration for multiple bus masters
  • Bus error or any other exception signaling

How to become Equal-Sinclair


Let's remove the Quad NAND IC. Will it still work?

If we remove the first NAND IC7D then we'll lose wait handling for the K1 bus. Ok, well, that may be acceptable. But we'll still need an inverter here to invert !SLOW_IO to !DTACK.

To solve this, we could connect A19 directly to !DTACK, so whenever the CPU accesses RAM or ROM !DTACK will be asserted. But then we'll lose !FAST_IO because whenever !DTACK is not asserted !VPA must be asserted instead to finish the bus cycle. So !VPA must be connected to !A19. How can we invert A19? We can use the unused gate from the Dual 2-to-4 decoder. If we have no fast I/O we also need no wait cycle handling. :-) Check.✓

If we remove the second NAND IC7C then we'll lose the !RD signal. This is acceptable: !OE of the ROM can be tied high so whenever the ROM is enabled it puts it's data on the bus. Disadvantage: If the CPU writes to the ROM then there'll be a collision on the data bus. We'll have to be cautious.

!OE of the RAM can also tied high. When !WR is enabled this will supersede the !OE signal. (eventually this is not true for all RAMs, but RAMs exist which can be operated in this way). Check.✓

If we remove the NAND flip flop, we'll no longer have the INIT signal. Ok, let's remove the resistor-diode OR gate as well and let's swap !ROM_CE and !RAM_CE. ROM has to be at address 0x00000 and we can't modify the vector table in ROM. Check.✓

Summary: Yes, we can become Equal-Sinclair! We just have no fast I/O and we'll have to live with the vector table in ROM. That's easy.✓✓✓

How to become Super-Sinclair


Obviously we must remove the Quad 2-to-4 line decoder as well. Will it still work? Ok, that's real hard, but Super-Sinclair IS real hard. You get a "Sir" for Equal-Sinclair, right?

First let's remove the gate used to construct the inverter for address line A19 which we just have added to become Equal-Sinclair. Now we have the choice: We could build an inverter from two resistors and one transistor or we could ... leave it out. Yes, that's what Sir Sinclair had done. :-)

We either need !VPA to be asserted during interrupt acknowledge or we must to supply a vector address. Both is possible:

Supply !VPA: Tie !VPA fixed low and !DTACK fixed high and the CPU will do all bus cycles in 6800 mode. Will be a little slow though. We'll have slow memory access and only slow I/O.

Supply !DTACK: Tie !VPA fixed high and !DTACK fixed low and the CPU will do all bus cycles in standard mode. We'll have fast I/O (with no wait cycles) but no slow I/O. During an interrupt acknowledge cycle we'll have to provide a vector number on the data bus. We can use a resistor network to pull up all data lines if no one else drives the bus, then the vector number will be 0xFF (255). Check.✓

Now – shiver! – let's remove the address range decoder. Can we provide !RAM_CE, !ROM_CE and !FAST_IO (no need for !SLOW_IO) somehow else?

Yes, we can! We can use 3 address lines directly to do that:
• Use A17 for !RAM_CE,
• A18 for !ROM_CE and
• A19 for !FAST_IO.

Drawbacks:
Each range is limited to 128 kByte. (A0..A16) Accepted.
There will be be bus collisions if the program accesses addresses with more than one of A17 .. A19 low. Accepted.
There may be short bus collisions when the address lines toggle between bus cycles. Accepted.
After reset the CPU will read from address 0x00000.l and 0x00004.l Uh uh... This will read from RAM, ROM and IO simultaneously. And any other vector will be read from this page with triple-collision as well. That's bad.

I'm a programmer and i'm here to find solutions: We have to disable RAM and IO when the ROM is selected. This will also reduce the forbidden address ranges with bus collisions.

We can get the RAM out of the way by its positive CE input. Yeah, it has one. Look at the circuit diagram. Just connect RAM.CE to A18 (!ROM_CE). When the CPU reads any vector from the first kByte of memory then A18 will be low and the RAM is not enabled. Check.✓

Next we can suppress the K1 bus control signals in a similar way: As you not yet know they are generated with a 3-to-8 line decoder 74HC138 which has two negative and one positive enable input. We can connect A19 (!FAST_IO) and !AS to the negative enables, and A18 (!ROM_CE) to the positive enable. Check.✓

Summary: Yes, we can become Super-Sinclair! We just have only fast I/O with no wait cycles, we'll have the vector table in ROM and we are limited to 128k ROM and 128k RAM and there is a risk of bus collisions if the program accesses forbidden address ranges and there may be regular very short bus collisions between each bus cycle.

Accepted. Design finished, let's ship it. ;-) Check✓ Check✓ Check.✓


Update: For completeness here is the main circuit of the Super-Sinclair design. Of course i won't build it this way, because, as said above, Super-Sinclair means reduced beyond usability.

Super-Sinclair 68008 Processor Board – no glue logics required


2014-01-14

New Project: 68008 Microcomputer

Servus,

one of my weird ideas is to build a microcomputer with every CPU i own. Ok, maybe not really *every*, but some of them i memorize with nostalgia. These are:
  • Z80 with SRAM
  • Z80 with DRAM and paged memory
  • 68008, one with SRAM and one with ~ 2MB DRAM SIMMs
  • 68000, let's see
  • 68020, eventually with FPU
  • 68040, with ~ 64MB DRAM PS2-SIMMs probably
All of them will connect to the K1 Peripheral Bus, so that half of the work is already done. ;-) Beyond that, no I/O will be implemented on these boards.

You see, in essence these are two processors. I started with a ZX Spectrum and proceeded with an Atari ST before i entered the world of Apple, Linux and not Windows.

68008 SRAM Microcomputer

Let's start with the 68008. I have both, the DIL and the PLCC variant. I'll use the DIL version for the SRAM board and the PLCC version for the DRAM board, because it can address more memory: 4MB instead of 1 MB only.

The 68008-SRAM  board will the half sized – 79x100mm – pretty tight, but it will fit. The 68k CPUs are a little bit nasty to integrate into a system, because they have quite a lot of requirements, especially the 68008 which implements an asynchronous bus model. But i'll use any trick, cheat and simplification i can find to make it fit. :-)

Basic Requirements

  • 68008 PDIP CPU
  • Eprom 32 .. 256 kByte
  • SRAM 128 or 256 kByte
  • K1-Bus half-sized card

Project Page


The Board

Layout v0.1 2014-01-14
To the left is a first layout of the board with all components required for the current circuit.

The top row ICs are glue logics.
To the left is the K1-bus connector.
The circuits to the left of the CPU connect the CPU to the bus.
The two 74HC573 registers expand the 8 bit bus of the 68008 to the 8 or 16 bit K1-bus.
The 74HC367 hex driver plus some resistors implements the i2c interface.
The 74HC138 decodes the strobe signals for the K1-bus.
In the center of the board is the CPU
and right of it the SRAM and the Eprom.


Requirements and Simplifications

• Memory Map. Memory is divided into 4 sections: RAM, ROM, fast I/O and slow I/O each of which is 256 kByte in size. This limits the size of the RAM and Eprom.

• CPU Clock. This is generated by a 10 MHz clock module. I avoid the hassle of generating the clock signal "by hand" with a quartz and inverters.

• CPU Reset. The 68000 family needs 0.1s low on Reset and on Halt for power-up initialization. This is currently done with some R and C and a Schmitt Trigger inverter.

• CPU DTACK. The 68008 needs an acknowledge for every memory read or write access. By delaying this signal you can add wait cycles. By never asserting this signal you can make the CPU hang for ever. This signal will be handled in the most simple way possible: It is tied to ground and this way always asserted. According to some other 68008 projects, where they do this for the test run on a bread board, this should work. Drawback: No wait cycles possible. I'll need a reasonably fast Eprom and SRAM. This also applies to the fast I/O.

• Bus Error. DTACK is always asserted and BERR is tied to Vcc. There will never be a bus error.

• Bus arbitration. The K1-bus does not support multiple bus masters and so does this board: bus request BR and bus grant BG are not used.

• Interrupt control. The 68008 PDIP has two interrupt input lines which can encode 4 states: no interrupt, 2 normal, prioritized interrupts and a non maskable interrupt. The only source for interrupts on this board is the K1-bus and so i need only one normal interrupt. The K1-bus supports prioritized interrupts by enabling/disabling interrupts directly on the attached extension cards.
Now the nasty thing: Devices must provide an interrupt vector during the interrupt acknowledge cycle. An automatic vector can be requested by asserting VPA and so we need to know when a bus cycle is an interrupt acknowledge cycle. For this we must decode the Function Code outputs FC0, 1 and 2 which are all '1' during an interrupt acknowledge bus cycle.

• K1-bus access. As said above there are two address ranges for the K1-bus: fast and slow.
The idea is to use a standard memory cycle for fast I/O where wait cycles are not supported because DTACK is permanently asserted. This is suitable for very fast peripheral cards and for switching interrupts and i2c on the K1-bus.
For slow devices i want to use 6800 peripheral I/O cycles by asserting VPA (valid peripheral address) in this address range. This will do a bus cycle synchronized with the free-running E output of the CPU (which has a fixed period of 10 CPU clock cycles) with at least 11 and at most 18 CPU clock cycles due to synchronizing; and no wait states because of the fixed alignment to the E signal. Eventually i'll come up with something better here.

• CPU VPA. This input was already discussed in two requirements above: Interrupt control and K1-bus slow access. During an interrupt acknowledge cycle it is pulled low to request an automatic vector (interrupt routine start address) and in slow I/O it is pulled low to request a slow 6800 peripheral bus cycle.

• K1-bus 16-bit I/O. Peripherals on the K1-bus may use 16 bit I/O. The 68008 has only an 8 bit data bus. There are two possibilities: I use it 'as is' and attach only 8-bit extension cards. Or i add 2 latches to store and receive the upper byte during a 16 bit I/O. I have some K1-bus cards which use the 16 bit bus, most namely the IDE board because IDE is 16 bit wide, and so i'll invest in two '573 data latches.

• K1-bus i2c. Peripheral cards on the K1-bus can have i2c EEproms to signal presence of and identify the card and to provide a universal byte-coded drivers. This costs one '367 hex driver IC plus some resistors. This makes it possible to add arbitrary cards to the microcomputer.

• ROM and RAM. The EPROM and the SRAM may be up to 256 kByte in size each. Due to space constraints only one SRAM IC is possible. Memory access cycles of the CPU are without wait states (see DTACK above) and therefore the memory ICs must be fast enough: Scrutinizing the bus cycle timing charts i expect that 150 ns access time will do it; eventually up to 200 ns will work.

• System Timer. There is no system timer on the board. Instead it is expected that one of the K1-bus cards supplies one. This is fairly easy, because my serial cards with one (or more) 88C192 dual UARTs can supply this.

• Serial and Parallel Ports. Any connection to the outer world requires a K1-bus extension card.

2013-02-03

Version 1.0 of i2c driver EEprom specification


Hello,

Version 1.0 of the specification for the driver i2c Eproms on the peripheral cards is finished.

I have also finished translation of the K1-Bus documentation, which was initially written in German.

Here are the links:

K1-Bus documentation: http://k1.spdns.de/.../K1-Bus/
Driver EEprom layout and bytecode: http://k1.spdns.de/.../K1-Bus/i2c-eeprom.pdf

    ... Kio !

2013-01-21

K1 Bus Update

Hello,

after i have worked for some months on my ZX Spectrum emulator, i'm now back for a while to the K1 CPU.

I worked on the draft for the driver i2c eeproms on the peripherial cards. They are going to version 1.0 soon. In the course i've started translating the K1 bus documentation, which was initially written in German. There is quite a lot of text to translate.

If you are interested, here are some links:

K1 bus documentation: http://k1.spdns.de/.../K1-Bus/
Driver eeprom layout and bytecode: http://k1.spdns.de/.../K1-Bus/i2c-eeprom.pdf

2012-07-18

XVGA TFT update

Hello,
i made some progress with the XVGA controller board.

Current State of the Board

First, it becomes more expensive, because it had to buy a minimum of 5 of the FPD-Link transmitter chips (note: i sell the others. Interested? ;-). Then the layout is very tight. See here:
2012-07-18 autorouted board
ICs placement is nearly final, then i'll add some more hand-routed wires, auto-route again and then hand-optimize. This will take a week or two.
I had real problems with the rams and FPD-link controller, they actually just fit between the '245 bus transceivers and the VGA connector. I tested a couple of arangements, but this produced the least vias.
FYI: bottom left is the 16 bit K1 bus, directly above two 74245 bus transceivers, the SMD ICs are RAM and the FPD-Link transmitter. 6 chips next to the right are drivers and drivers with latches, which are used to select between an externally supplied address (for the CPU reading/writing the video RAM) or internal address from the counter cascade, used to address the video RAM for display. Next 'column' of chips are the external address registers/counters, next are the internal address counter cascade, the vertical chips at the right are clock and ATtiny. Bottom right 6 ICs are the control logic. There's an I2C EEPROM sitting on the rear side of the PCB underneath the bus connector.
Though i us a 15-pin VGA SUB-D connector, the signal is not VGA but transmits 4 LVDS signal lanes, each 3 wires: pos. and neg. differental signals and associated GND. In addition one PWM signal is transmitted on pin 15 which will control the LCD backlight brightnes. According to what i found in the net this is a 5V 125kHz PWM signal.

Current Circuit

Here's an update to the circuit as well:
Circuit 2012-07-18 - Data Paths

Circuit 2012-07-18 - Control Logics


2012-07-04

XVGA TFT

Though i should finish the built LCDs first, i've already begun with 3rd display. I's a 1024x768 pixel TFT from my old iBook. It has a LVDS FPD-Link connection and i have searched the web for info about the panel and FPD-Link. I think i've got enough info to build it.

Major problems:

I need a special transmitter chip, preferably in 5V. These chips are generally hard to find (never used by hobbyists) and 5V is even harder. But i'll get a quote today. :-)
Timing is at the upper end of any hobbyists project: Pixel clock is 65 MHz, may be eventually lowered down to ~62 MHz.
This requires at least 15ns RAM, which will result in very tight timing, or better 12ns. And i need 1.5 MByte of it. Though i have plenty of RAM in stock, i opted to buy three 256Kx16Bit 12ns RAMs. Head count of ICs on the PCB is already very high.

Data flow on the XVGA controller
Control signals

Project Page

The project page is .../IO-Boards/VGA/ on my home site. This is on my private computer and everything i do here is directly visible on this page. Currently it contains a collection of spec sheets and the current state of the controller board design.


The Plan

The design ideas are as follows:
• The VRAM is addressed by a 20 bit counter cascade. Due to timing problems, the address is buffered by a set of 74574 latches, so the address is always one clock cycle delayed. The RAM output data is directly fed into the FPD-Link transmitter, which is clocked by the same clock signal. All running on 64MHz with a clock cycle of ~15ns.
• The slow signals, VSYNC, HSYNC and DE (Display Enable) are generated by an ATtiny. It also controls count enable of the address counters, to stop them during HSYNC and VSYNC (or, when DE is false). The ATtiny will be clocked with 16 MHz synchronously with the 64MHz pixel clock.
The ATtiny will also generate the FFB (frame fly back) interrupt signal, which is very important:
• VRAM access from the CPU will be completely asynchronously with the pixel access for the display. It will simply override the signals for the display, resulting in 'snow'. Each access will 'destroy' the display of approx. 3 pixels. This allows me accessing the VRAM without asserting the !WAIT signal on the bus. I have already checked the timing, writing is safe, reading is tight, but should work.
Accessing the VRAM requires sending an address and then one data i/o. The address is 20 bit, so it has to be transferred in two chunks. I opted to split the address in two 10 bit packages, which will directly translate into X and Y pixel address. To reduce the required bus transfers, i designed the address registers as counters as well. They will provide an auto-increment feature, so that i only need to set the start address and then can read or write in burst mode, hopefully with the full bandwidth of the bus of 16Mwords/sec. The X address can auto-increment, the Y address can auto-decrement as well. I probably can't make the X address easily auto-decrement, because i simply have not enough control lines to control this easily. The 'control lines' are the bus's address lines, and it has 6 of them.
To avoid the 'snow' effect when accessing the VRAM, i plan to do most i/o during the vertical frame flyback, which may be up to 10% of the total frame time. The exact maximum number of lines during ffb of my display will be determined when it is all built, therefore it's nice to have it programmable, because it's done by the ATtiny. It will be slightly tricky to align the control signals of the ATtiny with the 4-pixel boundary (ATtiny clock is Pixel clock ÷ 4) because the DE (display enable) signal for the FPD transmitter and the count enable signal for the address counter must not start and stop somewhere in the middle of a 4-pixel package but exactly at the start or end. Else the image on the TFT will be shifted some pixels, missing some at the left side and displaying garbage at the right side.

Let's see how it all works!

2012-06-27

The K1-16/16 CPU

The self-built K1-16/16 CPU, built with standard 74xx CMOS ICs

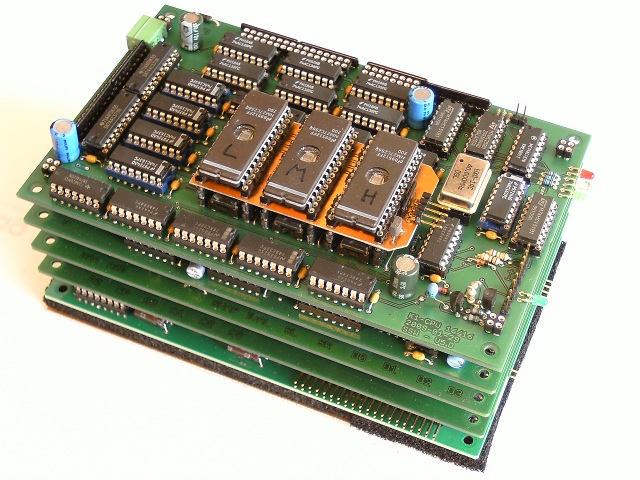
The K1-16/16 CPU is the heart of the self-designed and home-built K1-16/16 Computer.
It is built with CMOS ICs from the 74AC series and fits on 5 Euro boards (160 x 100 mm).

Sometimes you are struck by an idea...

Due to depressions programming became harder and harder. So i thought, why don't do something more simple, with more manual work? Electronics, for instance. And, thanks to the internet, i have already read from other maniacs, who built a 6502 CPU. Or a Z80 in FPGA. Or Dennis Kuschel's myCPU. And there's a web ring about it. If others can do this, it can't be that hard. Basically...
Of course my CPU should be Different. Better. And Simple, so that i can understand it myself. B-)
For symmetry i settled with a 16/16 bit design: 16 data bits and 16 address bits.

Unusual and Generally Interesting Parameters

• Combined Harvard and Von Neumann architecture
• 16 MHz system clock
  Front panel with slow motion clock for exhibitions et. al.
  Full static design down to 0 Hz
• 16 bit internal data bus
• 16 bit internal address bus
• 64k x 16 bit internal ram
• 32k x 24 bit microcode
  organized as 2 code planes à 16k for conditional execution and branching.
  the microcode is copied from eproms to rams during boot for increased speed.
  it is also possible to load the microcode from an external source instead.
  the microcode implements:
    boot code, BIOS, kernel
    100++ assembler opcodes for ram-based programs
    100++ millicode opcodes for microcode-based forth or c-style programs
• No flag register. (but flags)
• Built with discrete logics using 74HCxx and 74ACxx ICs
  CPU fits on 5 "Euro" printed circuit boards (160 x 100mm)
• Manual circuit design
  Manual routing of the PCBs (with EagleCAD)
  Professional made double-layer circuit boards

Harvard Architecture 

Programs can be written directly in microcode. Adopting this view, the K1 CPU has separated program and data memory. This is the Harvard Architecture.

Von Neumann Architecture

More likely, the CPU can also use a fixed microcode, which reads opcodes from the ram and executes them. Seen this way it has a combined program and data memory. This is the Von Neumann Architecture.

Start on blogger.com

Hello,
I'm building a CPU for 4 years now (more or less) and accompanied this on my home page k1.spdns.de. This worked quite well but i wanted to separate the blog from the project documentation itself and i wanted to enable some feed back. So i started this blog on blogger.com. I will move some stuff in here which previously was on my website; i'll see whether i can fix the dates.

     ... Kio !

2012-06-12

2nd Display

Going into mass production. ;-) I built a second, very similar LCD display which uses the same controller board. This one has a backlight, but it was CCFL. I had no inverter and building one and adapting it to the CCFL wold have taken too long and so i replaced it with an array of LEDs. Not good but working. See the photos on the LM64K101 - LCD Display 640x480 project page. Next is to debug the terminal software a little bit more and use it as output for the computer.

2012-05-26

Debugging the LCD Display Driver and Hardware


This week i worked on the 640x480 pixel b&w LCD terminal.  Soldering was easy, but fixing all the bugs took some time. I also had  to do some changes to the terminal code because i realized that i was using the LCD upside down.

I connected the LCD and powered the board through the programming  header. Off course nothing worked, except for the display refresh routine, which brought up a picture of the erased DRAM cells. Step by  step i brought up more functions: Erase screen, print characters, read  and write whole pixel lines and scrolling. I had to add some nops to the DRAM read and write timing, because the data goes through series resistors which create some delay. For the next board i'll reduce them slightly. Then printing of standard-size characters with 4 attributes in all combinations works.

 Finally one last important step: Attach it via serial line to USB to my Mac. Nothing worked. I adjusted the Baudrate on both sides. I printed text from the LCD terminal on the serial line in an endless loop. There was no signal on the TxD line. Why? But there seemed to be a signal on the RxD handshake line. ... ???

I had connected data lines to handshake and handshake to data lines on the board. :-(. Fixed it with a cutter, solder and wire. Tested. Worked. :-)

2012-05-19

Debugging i2c


And on it goes. The last days i spent finding out, why the i2c interface did not work. Hardware is ok, it's a problem with the software. First i thought, all i2c eeproms have a block size of 64 bytes. But that's not that easy. Block size varies with eeprom size. And manufacturer… :-| But most 8k eeproms have blocks of 32 bytes and most 16k and 32k eeproms have blocks of 64 bytes.

Then busy polling after a block write did not work properly. I started a read cycle to detect the busy state (the eeprom does not respond if busy) but this behaviour is only defined if you start a write cycle. So i rewrote my source to do this.

Then somehow my start and stop sequences on the i2c bus sometimes failed. Now i test-read the data line to see if it is high and not pulled low by the target, for whatever reason.

Now access to the K1 bus eeproms works properly and hopefully reliably. I successfully downloaded the SIO driver code into the SIO driver eeprom and booted the CPU with driver initialization from eeproms, and not with data from the microcode. And it works! :-)

And, last not least, selecting the i2c eeprom on a K1 bus card works as planned: All eeproms are addressed with address 0b000, but only the eeprom on the currently selected extension card actually has this address. The i/o cards disable their eeprom while they are not selected, and the easiest way to do this is to set any address pin of the eeprom to '1', so that the address does not match.

2012-05-14

Debugging the SIO board


Instead of writing some 'useful' commands i spend the last days tracking down a weird error. When i activated the timer interrupt of the 88C192 UART to give me a system timer interrupt of 100 Hz, the whole system got stuck. The simulator worked, the real hardware stalled. Bad!

It took me some time with the minimalistic debugging facilities to come to the conclusion, that the interrupt does not go away. When i rewrote the RETI (return-from-interrupt) opcode to execute the next  opcode regardless of interrupt state the system made it to the shell prompt, though eating all the cpu power. This only happened when i enabled the timer interrupt, else everything seemed to be ok. I double checked my code three times. Have i a broken UART? Is the documentation wrong?
Finally, when i programmed the UART to the longest possible duration, this left ~90% cpu time in the 'Halt' state (at 8MHz). Some observations later i discovered, that interrupts came in bursts. I measured the burst rate: ~3.5Hz. I did a calculation of the interrupt frequency: 7.372MHz/32/0xFFFF = 3.515Hz. This proved, that the timer interrupt generated the bursts.

But why did the interrupt stay active for ~1/35 sec (given the 10% cpu usage) and then go away? I examined my circuit design very carefully ... VERY carefully ... this whole thing looke like a ... and there i got it: The /INT output of the UART is open collector and i had no pull-up resistor fitted there! Now all observations made sense. I soldered a 5kΩ resistor between 2 suiting pins, restored the SIO eeprom driver, compiled the microcode rom, uploaded it to the front panel, resetted the cpu from the front panel eeproms and yepp, it worked! :-) The timer interrupt now eats approx. 1% (at 8MHz).

2012-05-02

Debugging the CPU

2012-05-02

I'm now moving back from emulation to the real hardware. I expected problems, and there they are.
Somehow upload of microcode files to the front panel did not work. First it hangs with XOFF, so i disable XON/XOFF and lower the baud rate. Then it transfers up to address 0x4A00 and aborts with an error. Each time i try to do 'something' to find out the cause the error changes. Finally i find out that at that position is the first unused gap in the microcode and obviously refresehing the LCD is so time consuming that even the longest delay after one line of code (100ms) is not enough. Strange, when i re-enabled XON/XOFF it worked. So microcode upload to the CPU is working again.
Fundamental Timing of the K1-16/16 CPU
Now the code does not make it beyond the initial register test. Loading the SR (shift-right) register failed to load the CY input to data bit D15. I remember that there was a problem with exactly this when i tested it more than one year ago. I had settled my mind it was a contact issue and tried to prove this now again. But it isn't. Actually the little chart with the fundamental timing of the CPU contains the secret:
The blue clk is the load signal for the registers – SR is a register – and the rising edge is where it latches new data from the data bus and, in case of data bit D15, from the CY line. The CY line is a 'option control' line, it controls options in the various registers, if they have. As can be seen in the image the option control line toggles exactly at the same moment (if it toggles) when the clk line raises. So we have a race condition here.
The only thing i can do is to delay the CY option control line for the shift registers. I examined whether this problem will show up at other places too, but it seems not. Whereever CY (or any other option control line) is used, there are some gate delays between the option control line and the data latching register. So it's enough to delay this signal for SR and SL only. Luckily there is an unused OR gate on the data registers board which i will use for this.

2012-05-03

All test code performed without error. :-) Except for i2c test, because i have not yet attached any io device.

2012-05-04

Weekend … phantastic weather … what to do? ok, i manufactured the K1-system-bus. ;-)

2012-05-05

Tata! The SIO board works. Today i got the console prompt on the terminal. There are still some issues to examine: Speaking to the i2c eeprom did not work. The hardware seems to work properly, but the eeprom does not respond. This is to be investigated. Whether interrupts work as expected is still to be tested. Though they seem to work.

2012-05-06

Yep. Interrupts obviously work. SIO works: i/o to serial to my Mac works and i/o to the front panel works. Now i'll have to add some extras to the terminal in the frontpanel, e.g. handle some control codes. ;-) And then add some stuff to the boot shell of the computer, like cd, ls and so on. And investigate the i2c problem.

2012-03-26

SIO, IDE and Terminal

2012-03:

SIO board
I have used the wrong SO-8 package in the drawings for the SIO and IDE board and had to place the I2C EEprom very carefully on the PCB to solder it. The pins extended beyond the solder pads, but it seemed to work.

2012-03-17: Heart attack: i took a look at the 88C192 SIO's PDF and saw that pins were numbered starting at a corner. X-( .... but this was for the TQFP-44 package only. Pin numbers of the PLCC package start in the middle of one side. HTF were these brain dead idiots... ?


IDE board
Soldering the 50 CF card adapter pins went quite well: Some flux applied in advance, soldering the pins with as little tin as possible, ignoring all junctions and blobs of tin and then removing most of the solder tin with desoldering wick. perfect. Stacking of the CF card and an IDE Flash drive works as desired.
LCD driver board
I hope everything will work. Testing starts ... soon. :-]
 2012-03-26: The PCB for the above mentioned LCD display project arrived. Yet another board to test and to write software for. But this one is easier.

2012-02-22

SIO and IDE Cards


After a long time where i played around with the C-style compiler for the microcode, which i expanded to a virtual instruction code compiler for use on my Mac, i resumed work on the half-sized IDE interface and the half-sized serial adapter. The IDE interface will connect two devices, a 96 MB DiskOnModule with a 40 pin IDE connector and a CF adapter for removable drives. The serial adapter will only be used temporarily for the K1-CPU itself. It will be replaced by a 4 channel (or evtl. more) serial card later which will also incorporate a LAN adapter module, which i own. The serial ports can be used for asynchronous communication with SW or HW handshake or with clock signals of any polarity. XOR gates are useful programmable inverters. ;-) The 88C192 chips have idiotic restrictions for the selectable bit rates. :-|
The two boards have been ordered on 2012-02-04 from Leiton, like the others.
Related to the CPU project is another project which i was working upon the last two weeks: A controller board for an old black&white reflective LCDisplay i own. It is based on an ATMega8 and uses old 41464 DRAM chips for it's frame buffer.
20212-02-22: The IDE and SIO boards arrived. I got two of each, due to overproduction, for fair additional costs. But the boards don't look good this time. Like processed in over-aged chemicals or the like. I don't know.

2011-07-15

Serial and IDE Cards

Currently i'm working on the microcode again. I reworked the existing c-code to match the new compiler and started work on device drivers and file system. Some peculiarities were introduced due to the pure 16 bit design of the CPU.
Also, i started the design of a half-sized serial card for the K1 bus and a half sized IDE card. When these are built i can restart working with the real CPU. But i'll probably test them in the emulator first. For the IDE card i have the choice to use a 96MB 40-pin IDE flash rom module or a compact flash adapter. Combining them may be a little bit tricky because IDE uses TTL levels and compact flash CMOS levels.
For the serial card i'm using an 88C192 which can also provide a regular system timer interrupt.

2011-04-15

Vicci 's got a name


The last months i was busy rewriting the compiler in C++. Meanwhile it evolved into a fully fledged compiler/linker/virtual code interpreter for i386/i386x64/ppc. Now most things work and i'm starting work on the K1-CPU [microcode] assembler backend.